Visuomotor Robotic Pruning in Planar Orchards Using Hybrid Reinforcement Learning

Sep 1, 2026·
Abhinav Jain
Abhinav Jain
,
Cindy Grimm
,
Stefan Lee
· 1 min read
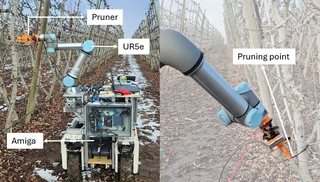
A UR5e robotic arm with a custom pruning tool on a Farm-NG Amiga platform performing zero-shot sim-to-real pruning in a real V-Trellis apple orchard.
Abstract
Dormant tree pruning is labor-intensive yet essential for maintaining modern high-productivity fruit orchards. In this work, we focus on pruning of modern planar tree training systems—V-Trellis apples and UFO cherries—where trunks and primary branches are trained into approximately planar walls. We introduce an end-to-end pipeline to learn a closed-loop visuomotor controller for robotic pruning. This controller is trained entirely using simulation and synthetically generated data and deployed in real orchards in a zero-shot manner. The pipeline comprises synthetic generation of planar orchard tree meshes, construction of a physics-based orchard simulator, automated collection of successful pruning trajectories via motion planning, and policy learning with a novel hybrid reinforcement-learning algorithm (Hybrid-PPO) that combines offline demonstrations with online simulated rollouts. The controller uses optical-flow inputs from a wrist-mounted camera—avoiding the need for full 3D-reconstruction—and continuously guides the cutter through cluttered branch environments to a specified cutpoint with correct tool orientation. In exhaustive simulated task-space evaluations over 3,000 pruning points, the policy attains 49.9% success on V-Trellis apples and 46.0% on UFO cherries. We validate the learned controller across 38 physical trials—comprising 28 outdoor field trials in commercial and experimental orchards and 10 indoor laboratory tests—demonstrating zero-shot sim-to-real transfer. The learned policy also outperforms a classical RRT-Connect baseline on physical hardware in laboratory trials.
Type
Publication
IEEE Transactions on Field Robotics, Special Issue on Precision Agriculture and Forestry
publications

Watch the Demo

See the visuomotor policy achieving zero-shot sim-to-real transfer in real commercial and experimental orchards:

Abstract

Dormant tree pruning is labor-intensive yet essential for maintaining modern high-productivity fruit orchards. In this work, we focus on pruning of modern planar tree training systems—V-Trellis apples and UFO cherries—where trunks and primary branches are trained into approximately planar walls. We introduce an end-to-end pipeline to learn a closed-loop visuomotor controller for robotic pruning, trained entirely in simulation and deployed in real orchards zero-shot.

Key contributions:

  • Novel orchard simulator: Physics-based PyBullet environment with synthetically generated planar orchard tree meshes (Tree-L-Py)
  • Automated demonstration generation: Motion planning pipeline (RRT-Connect) to collect successful pruning trajectories as offline data
  • Hybrid-PPO: A novel hybrid reinforcement-learning algorithm combining offline expert demonstrations with online PPO rollouts
  • Optical-flow perception: Avoids 3D reconstruction; wrist-mounted camera optical flow enables strong sim-to-real generalization
  • Real-world validation: 38 physical trials (28 outdoor field trials in commercial orchards + 10 indoor lab tests) with zero-shot sim-to-real transfer; outperforms RRT-Connect baseline on hardware

Simulation results: 49.9% success on V-Trellis apples and 46.0% on UFO cherries (3,000 cutpoints). Real-world results: 71% success on V-Trellis apples in outdoor commercial orchards.

Abhinav Jain
Authors
PhD Candidate in Robotics
Soon-to-be Ph.D. graduate in Robotics and AI researcher specializing in robotic mamipulation. Skilled in complex simulation design using Isaac Sim and Isaac Lab, and sim-to-real transfer for unstructured, real-world orchard environments. Expertise in creating novel RL algorithms, applying Deep Reinforcement Learning and Imitation Learning to deploy robust manipulation policies on physical robotic platforms. Recognized for research contributions in top-tier conferences (ICRA, CVPR, AAAI), with proven experience in synthetic data generation and training RL, generative AI, and Large Language Models (LLMs).